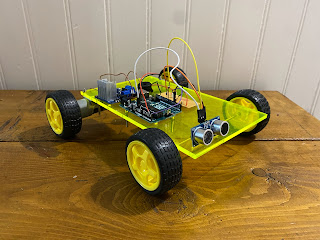
Purpose of Project: We will be designing and making a metal detecing, obstacle avoiding robot. The robot will be able to move along a set path and avoid any obstacles in that path. The robot will have the ability to detect any metal object that it drives over and will then alert the user of the objects presence using a buzzer. The robot will be controlled using an arduino which we will program. Main Components: Arduino Uno - The brain of the robot. Interfaces with the other components. Dual H-Bridge Motor Driver Module - Controls the two motors. Geared Motors - Used to move the robot. Ultrasonic Distance Sensor - Used to detect incoming obstacles . Buzzer - Used to indicate when the robot detects a metal object. Insulated Wire - Used in making the metal detector coil. Chassis - Every other component gets mounted to the chassis sop that the robot is one ocherent piece. Week One Progress: This week time was spent on figuring out how to use the arduino, how to pro...



Comments
Post a Comment